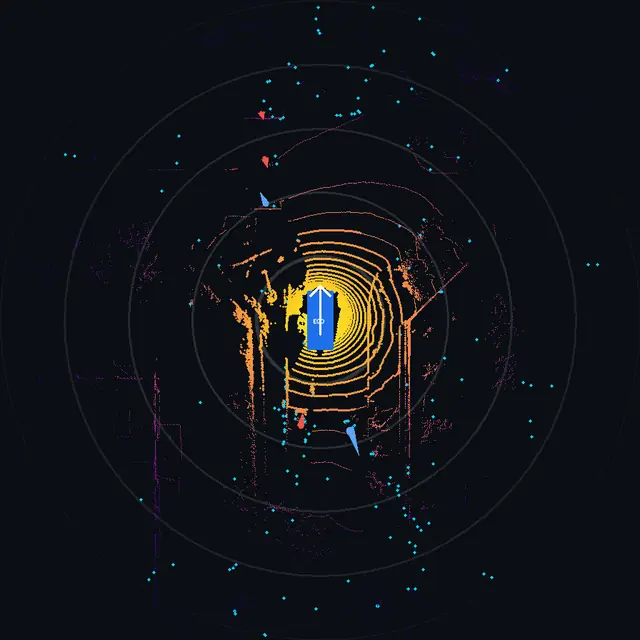
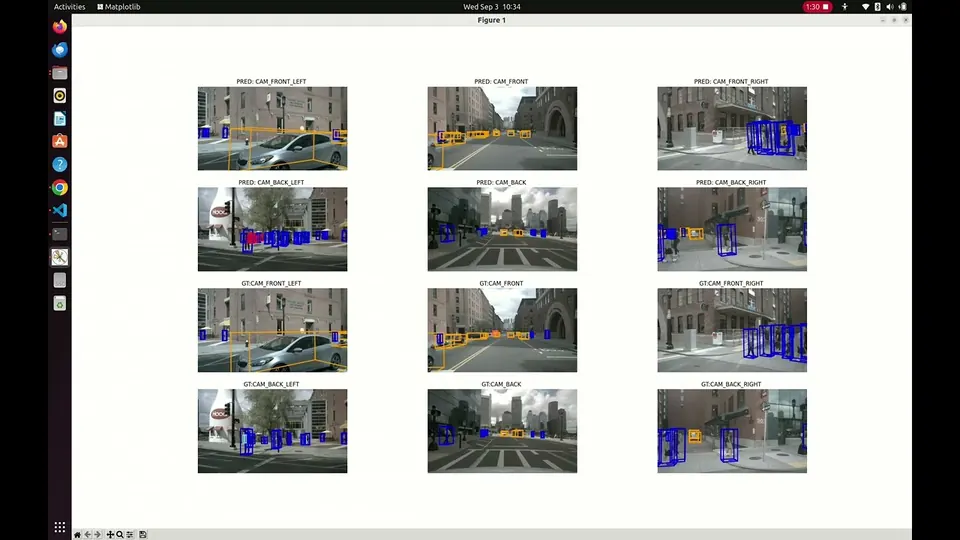
MoRAL: VLM for Autonomous Driving and ADAS Reasoning
NVIDIA Cosmos Reason 2: first it learns to read a bird's-eye view from LiDAR and radar, then it reasons about driving decisions. Presented at IEEE IMC 2026 in Fukuoka.
PyTorch · VLMs · nuScenes · BEV · LoRA
ROS 2 connected course
ROS 2 notes I used while teaching: first node through Nav2, plus Jetson vision.
ROS2 · MkDocs · Gazebo · Nav2 · Jetson
Isaac Sim in Docker
Run Isaac Sim in Docker and stream it over WebRTC so you don't need a local GUI install.
Isaac Sim · Docker · WebRTC
PS5 DualSense ROS2 wrapper
Haptics, sensors, and touchpad for humanoid and robot teleoperation.
ROS2 · C++ · Python
Multi-modal sensor fusion
LiDAR plus cameras for real-time mapping and detection on NVIDIA Orin.
ROS2 · ORB-SLAM3 · NvBlox · LiDAR
LiDAR calibration for indoor AV
Base-station LiDAR with a vehicle LiDAR for indoor autonomous driving (I2V).
LiDAR · Calibration · ROS2
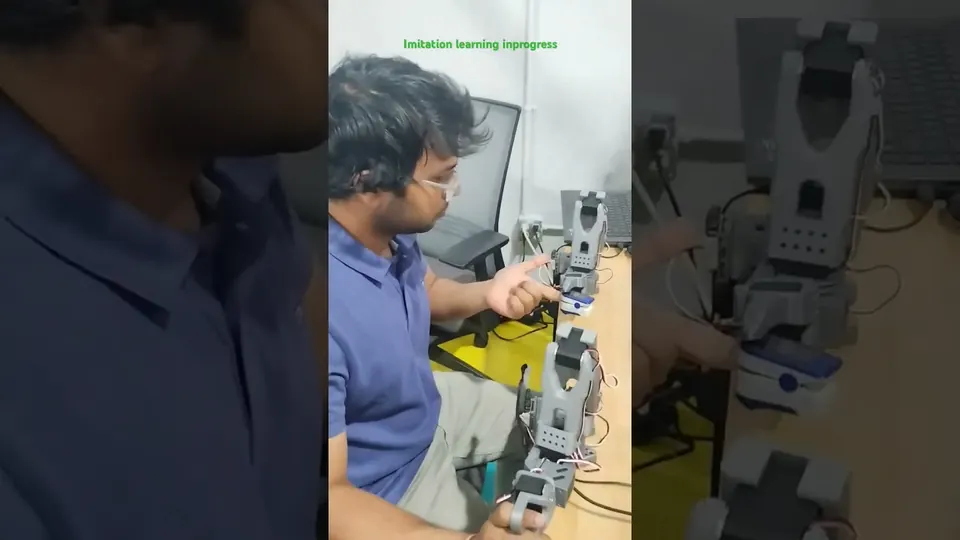
LeRobot imitation learning
Imitation learning on an SO-101 arm at a Hugging Face LeRobot hackathon.
Python · LeRobot
IoT Trojan Image Scanner
Detects trojanized images through anomaly and file-integrity analysis.
Python · OpenCV · Docker
TheRobotSim: IoT Simulator
Hardware-aware simulator for IoT devices and robotic agents.
Go · HTML · IoT
ZED Camera 3D Mapping
ZED camera on Jetson Nano for 3D maps used in autonomous navigation.
Python · NVIDIA Jetson · ZED SDK