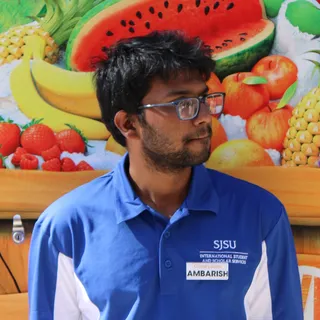
Headshot of Ambarish Govindarajulu Kaliamurthi

Hey, I'm Ambarish

Ambarish Govindarajulu Kaliamurthi

I wanted to work on machines that move through a room, not only through a dataset. That's why I spend my time on humanoids and perception.

Robotics Engineer @ Toborlife.ai · M.S. Computer Engineering, SJSU · IEEE IMC 2026

Authorized to work in the US. Open to robotics roles.

Currently working on

At Toborlife I help design the full loop on Unitree G1 and Go2: teleop and data collection, training VLAs (Isaac GR00T N1.7, Cosmos Reason 2 and Cosmos 3), and running them on Jetson Thor/AGX. I care about real-time latency, and about keeping the stack in line with current research and how the industry actually ships. The aim is a platform so more people can do this end to end, not only the few who already know every step.

Working on a Unitree G1 humanoid: open torso, boards, and arm joints
Working on a Unitree G1 at Toborlife

Publications

MoRAL: Sensor-Grounded BEV Reasoning for Compact VLMs toward Edge-Oriented Autonomous Driving

Ambarish Govindarajulu Kaliamurthi, Kaikai Liu · IEEE IMC 2026, Fukuoka (presented) · arXiv:2608.02449

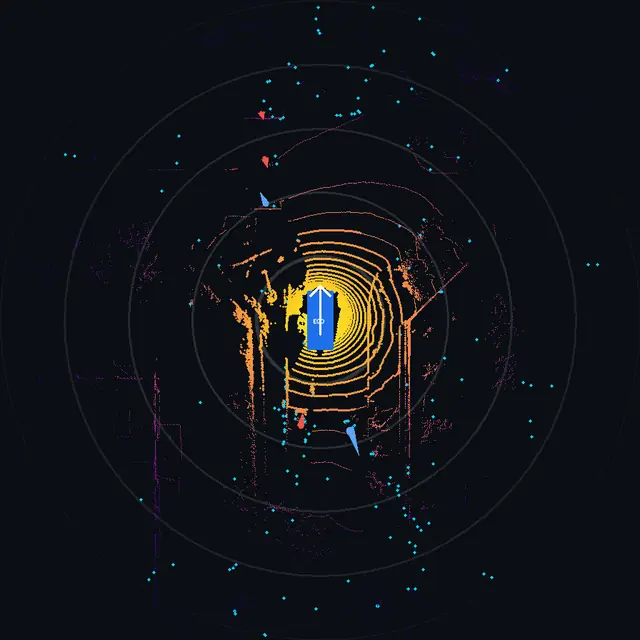
I taught NVIDIA Cosmos Reason 2 to read a bird's-eye view we render from LiDAR and radar, then to reason about driving: what is approaching, whether to brake. Two stages: learn to read the scene, then learn to decide. Presented at IEEE IMC 2026 in Fukuoka.

Bird's-eye-view sensor plot: ego vehicle at center, LiDAR points and tracked objects around it
Bird's-eye view of a scene, the kind of input MoRAL reasons over
Experience

Robotics Engineer · Toborlife.ai

July 2026 to present. Helping design the teleop-to-VLA pipeline, with an eye on latency.

Graduate Research Assistant · SJSU

Sep 2024 to May 2026 · MoRAL, AMR stacks, LiDAR fusion, Jetson fleet.

Software Engineer · Smarthub.ai

May 2021 to Jan 2024 · 10K+ cameras, YOLO in production, 97% faster OTA.

Full experience

Skills

Physical AI
Isaac GR00T N1.7 Cosmos Reason 2 Cosmos 3 π0 Isaac Teleop Gear Sonic
Robots and edge
Unitree G1 Go2 Jetson Thor Jetson AGX ROS 2 Isaac ROS Isaac Sim
Perception
LiDAR BEV NVIDIA Warp PyTorch LoRA

Selected work

Bird's-eye view of a driving scene used by MoRAL

MoRAL

A small Cosmos Reason 2 model that reads a bird's-eye view of the driving scene, then reasons about what to do. Presented at IEEE IMC 2026 in Fukuoka.

PyTorch · VLMs · nuScenes · BEV · LoRA

ROS 2 course

ROS 2 course

ROS 2 notes from teaching and from getting Jetsons to cooperate. First node through Nav2.

ROS2 · Gazebo · Nav2 · Jetson

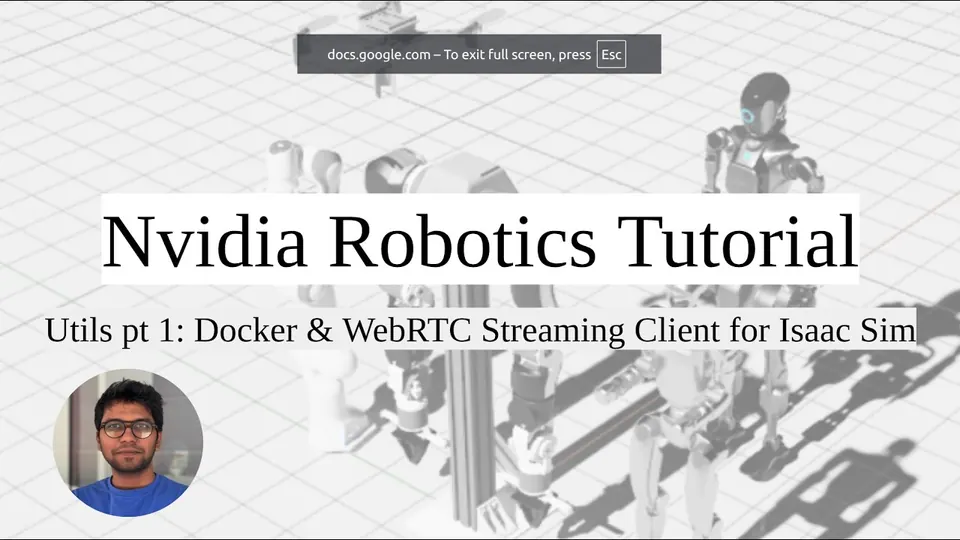
Isaac Sim running in Docker

Isaac Sim in Docker

Run Isaac Sim in a container and stream the GUI over WebRTC.

Isaac Sim · Docker · WebRTC

All projects Watch tutorials

Open to robotics roles. Authorized to work in the US. Connect on LinkedIn

Say hello

Happy to talk about robotics, the paper, or the tutorials. LinkedIn or email is fine.

Contact me